Kota Kondo
Stanford Multi-Robot Systems Lab | VLMs | VLAs | World Models | Manipulation | Humanoids

I am a postdoc in the Multi-Robot Systems Lab (MSL) at Stanford University, working with Professor Mac Schwager. My research focuses on vision-language models (VLMs), vision-language-action models (VLAs), and world models for robot manipulation and humanoid robots.
I received my PhD from MIT AeroAstro in 2026, where I worked in the Aerospace Controls Lab (ACL) under the guidance of Professor Jonathan How. My PhD research focused on safe and fast trajectory planning in unknown dynamic environments, including spatiotemporal trajectory planning, multiagent trajectory planning robust to communication delays, heterogeneous robot teams, learning-based multiagent trajectory planning utilizing diffusion models, and perception-aware and uncertainty-aware trajectory planning. Before that, I worked on detumbling an under-actuated spacecraft with a single-axis magnetic actuator and quadcopter path planning with an onboard EMPC controller.
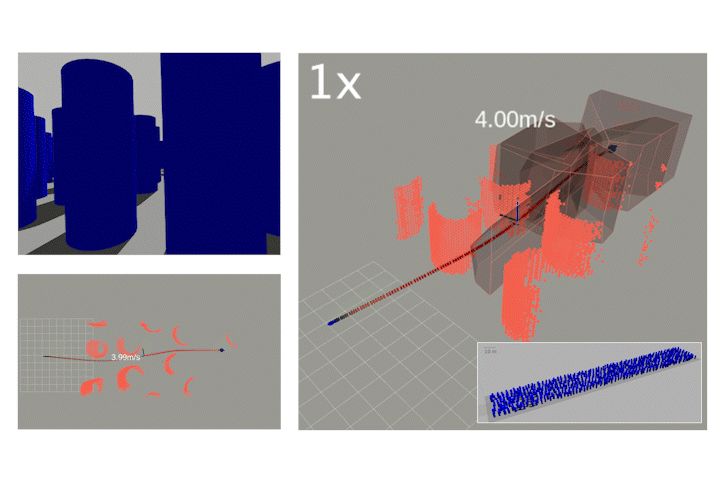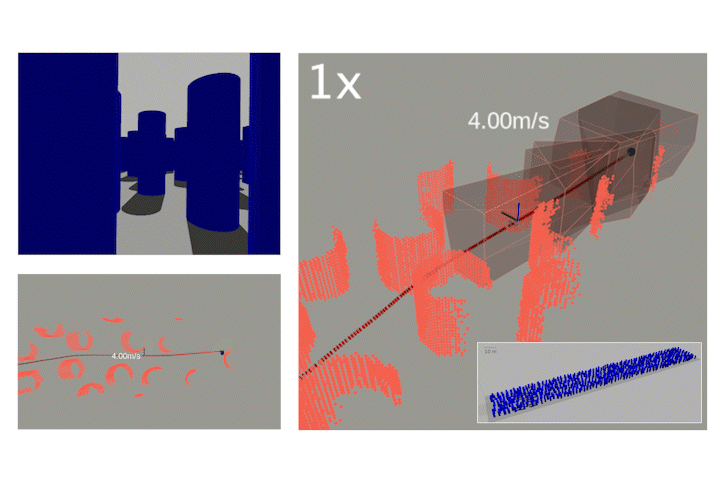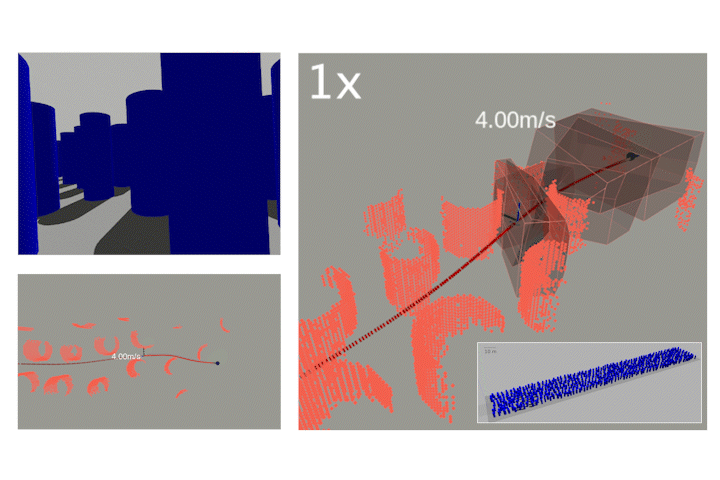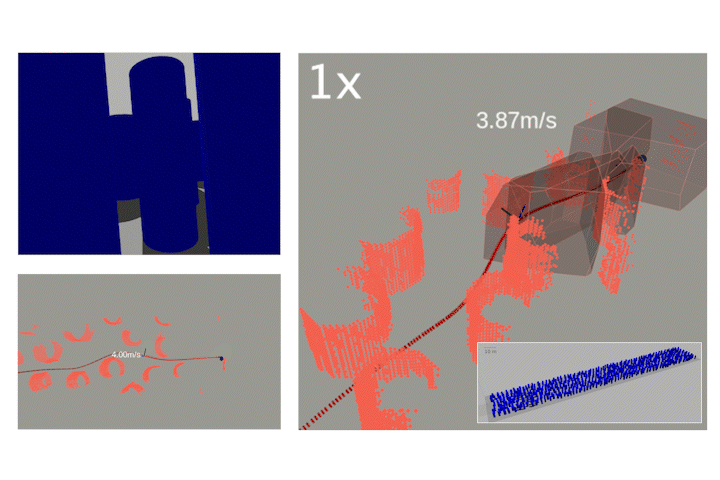
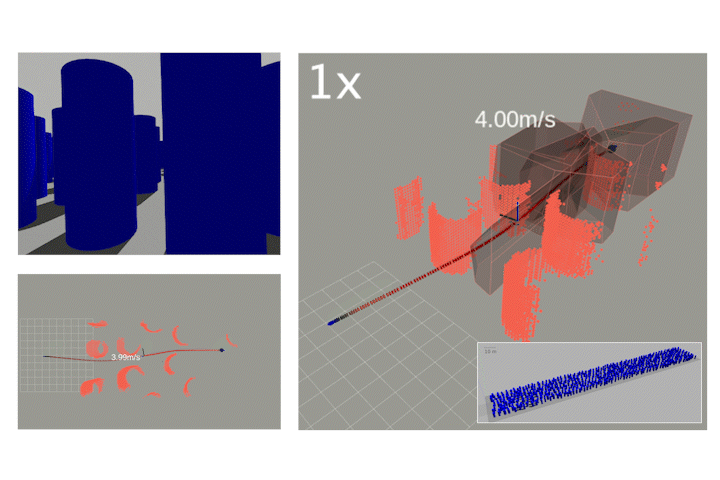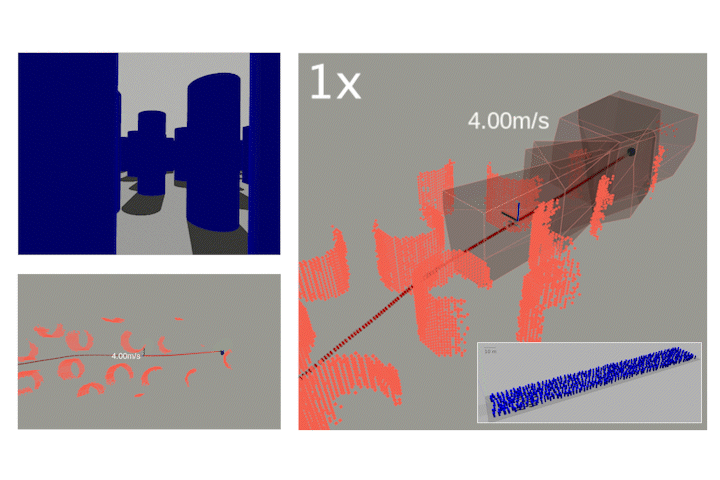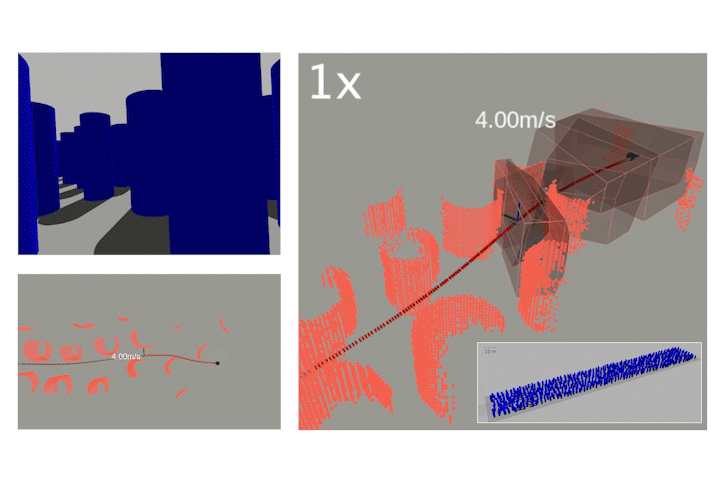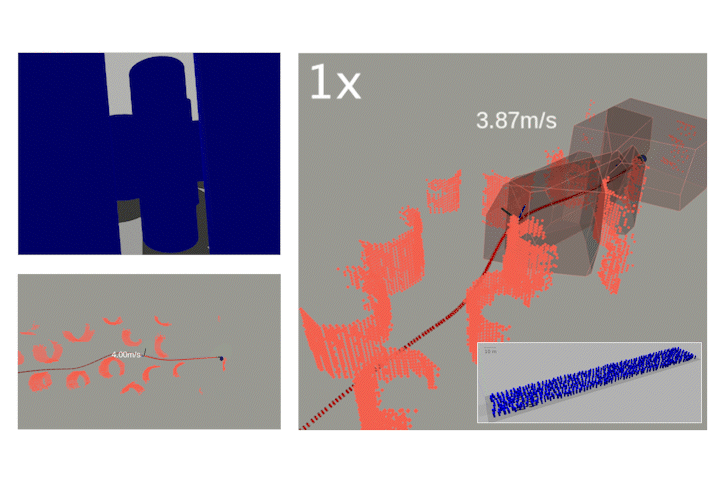
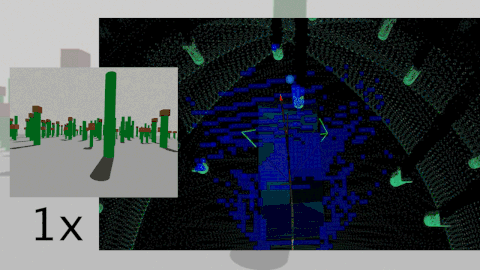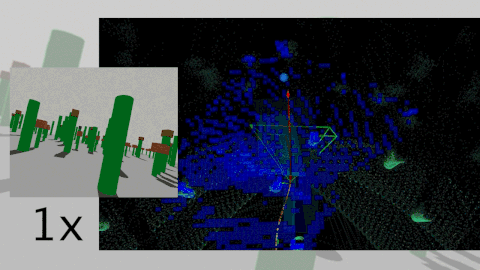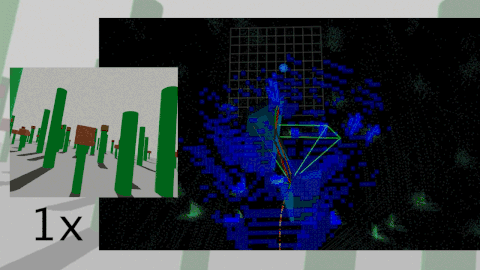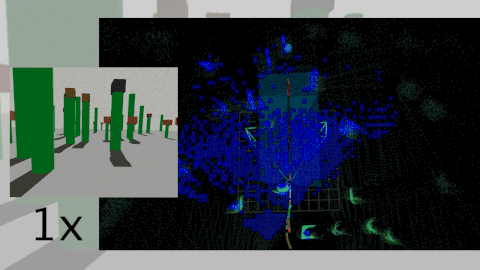
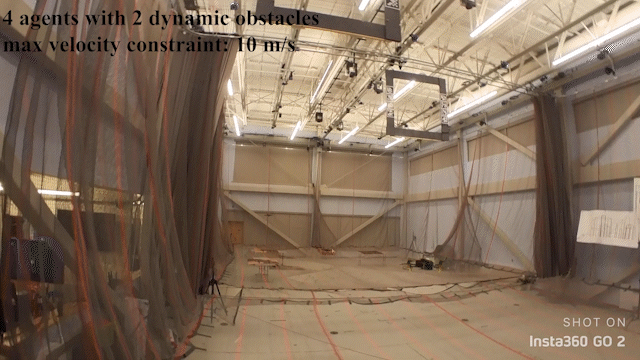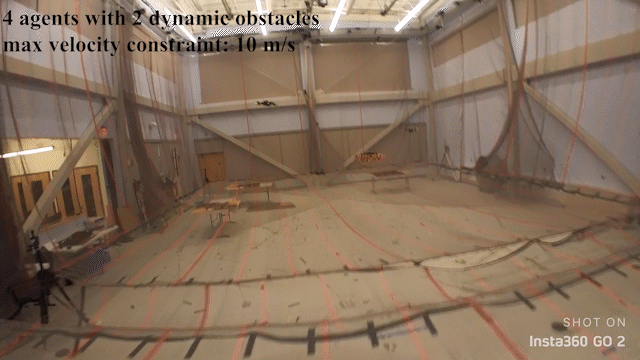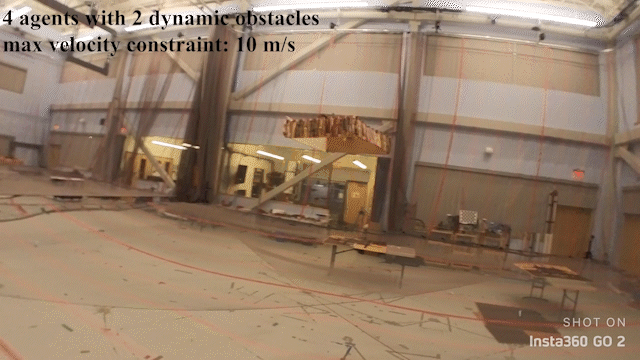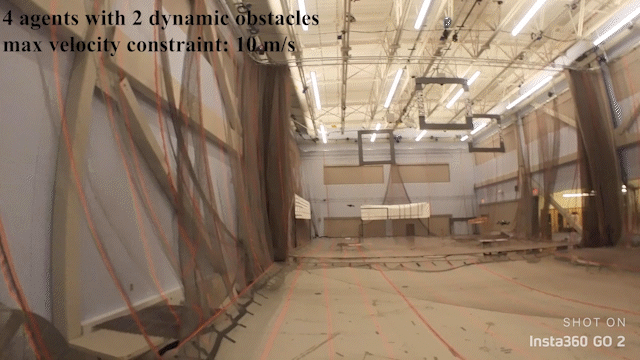
SANDO: Helping Robots Avoid the Unexpected (MIT)
news
| Oct 2026 | SANDO featured in MIT News: Planning system ensures a robot’s flight path will remain collision-free. |
|---|---|
| Oct 2026 | SANDO accepted to IEEE Transactions on Robotics (T-RO). Paper / Code / Video |
| Oct 2026 | Started a postdoc at the Stanford Multi-Robot Systems Lab (MSL) with Prof. Mac Schwager, working on VLMs, VLAs, and world models for manipulation and humanoid robots. |
| Sep 2026 | Presented Multi MIGHTY at the IROS 2026 Workshop on Tightly Coupled Physical Interaction and Collaboration in Multi-Robot Systems. |
| Sep 2026 | Gave an invited talk at the University of Pennsylvania. |
| Jul 2026 | STORM accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026. Paper / Video |
| Jul 2026 | Successfully defended my PhD thesis Safe and Fast Trajectory Planning in Unknown Dynamic Environments. Video |
| Jul 2026 | SANDO conditionally accepted to IEEE Transactions on Robotics (T-RO). Paper / Code / Video |
| May 2026 | MIGHTY featured in MIT News: New research enables a robot to chart a better course. |
| Apr 2026 | Submitted SANDO: Safe Autonomous Trajectory Planning for Dynamic Unknown Environments to IEEE Transactions on Robotics (T-RO). Paper / Code / Video |
| Apr 2026 | MIGHTY accepted to IEEE Robotics and Automation Letters (RA-L). Paper / Code |
| Nov 2025 | Submitted MIGHTY: Hermite Spline-based Efficient Trajectory Planning to IEEE Robotics and Automation Letters. Paper / Code |
| Sep 2025 | Paper on Efficient Navigation in Unknown Indoor Environments with Vision-Language Models accepted to IROS 2025 OWN Workshop. |
| Apr 2025 | Submitted DYNUS: Uncertainty-aware Trajectory Planner in Dynamic Unknown Environments to IEEE Transactions on Robotics. Paper / Code |
| Sep 2024 | Submitted PRIMER: Perception-Aware Robust Learning-based Multiagent Trajectory Planner to IEEE ICRA 2024. Paper |
| Aug 2024 | Selected as MathWorks Fellow. MathWorks fellowship provides support to graduate students within the School of Science with a preference for students who are active users of MATLAB and/or Simulink. |
| Jul 2024 | REAL accepted to IEEE Conference on Decision and Control (CDC) 2024. |
| Jun 2024 | SOS-Match accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2024. |
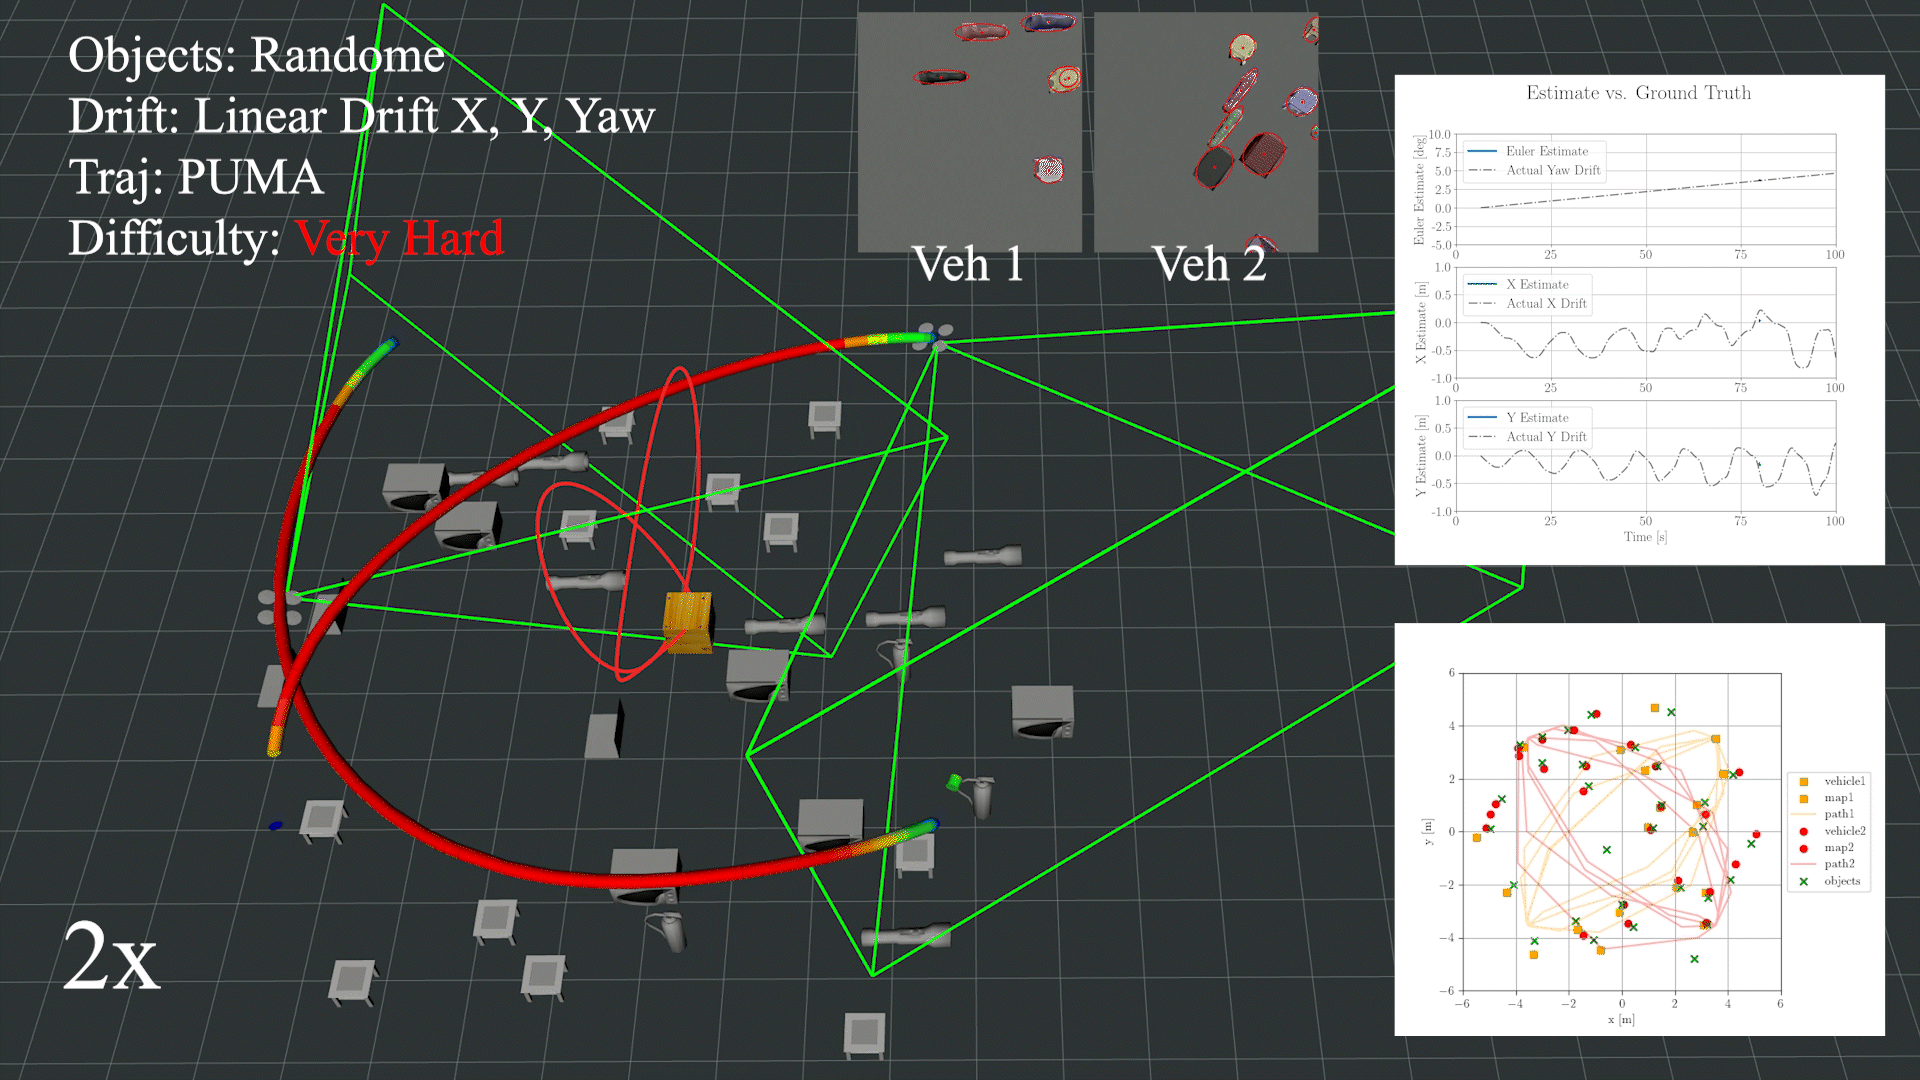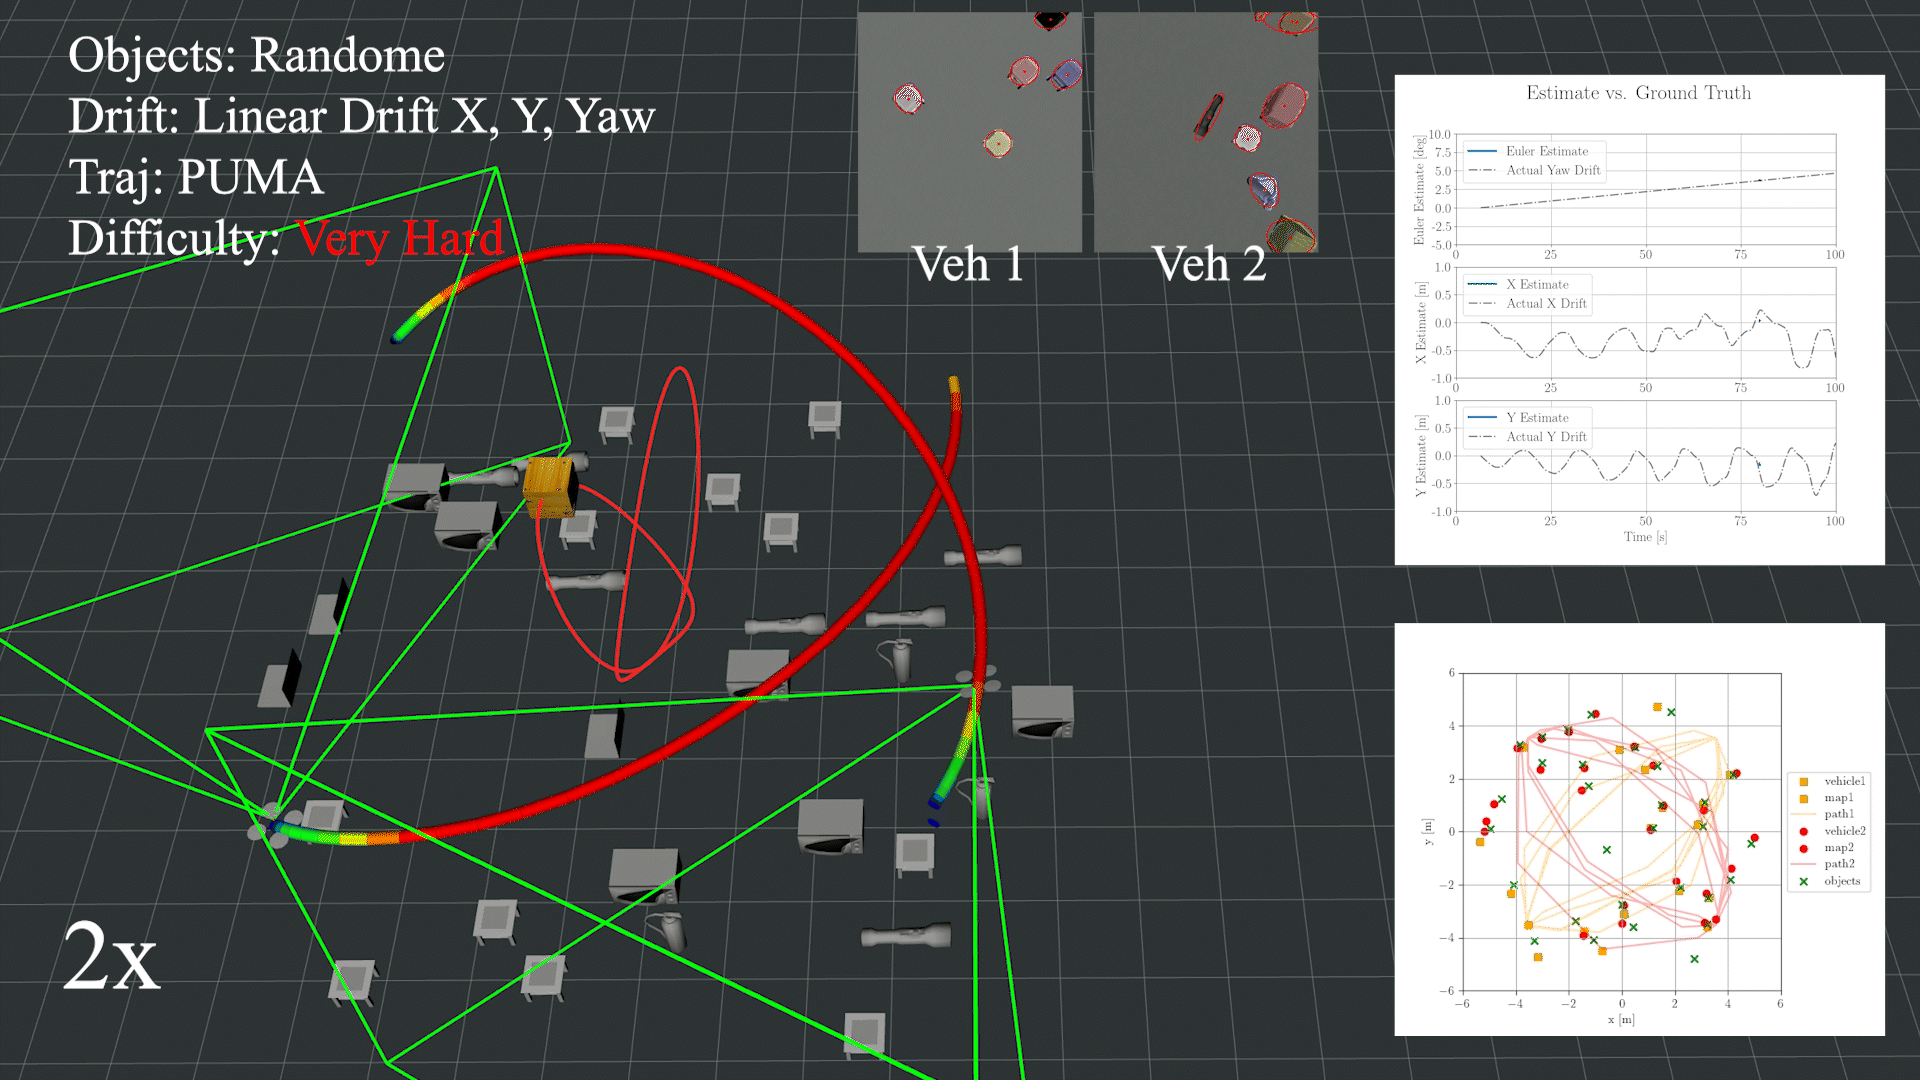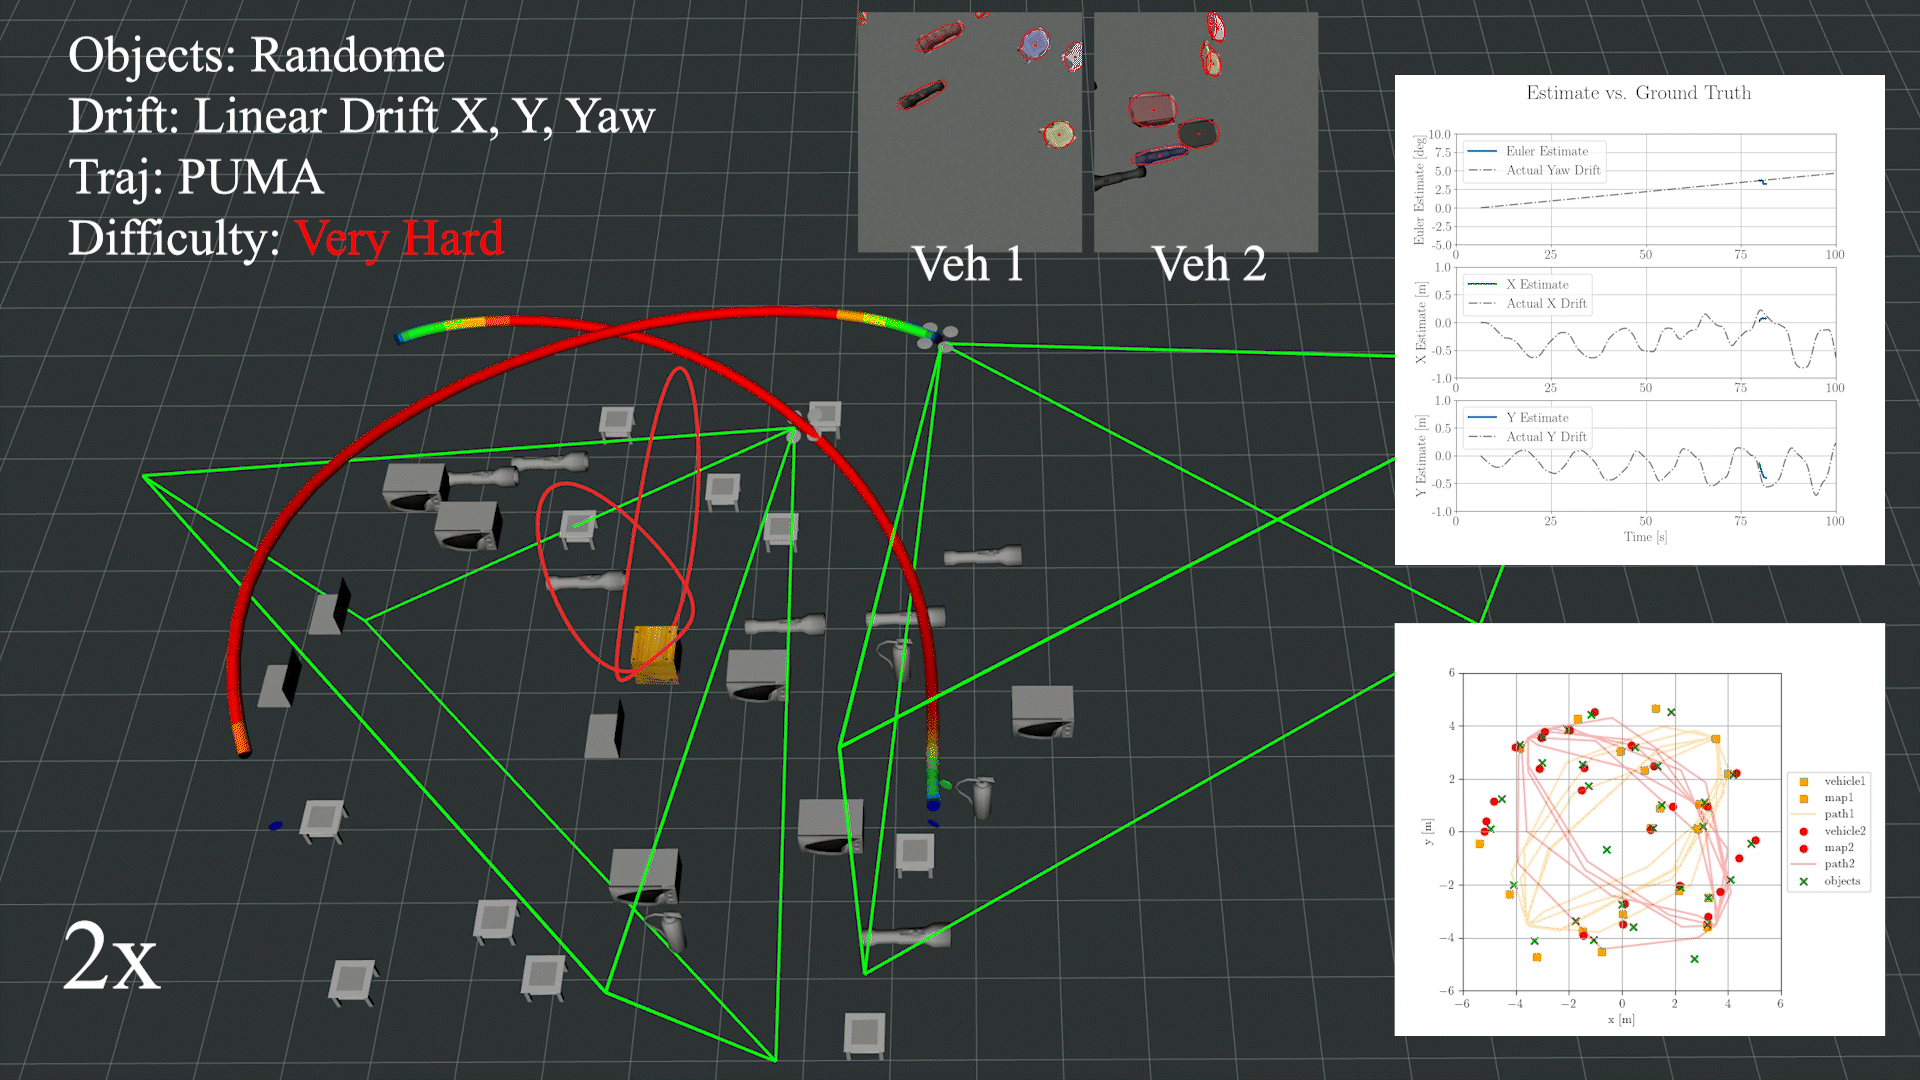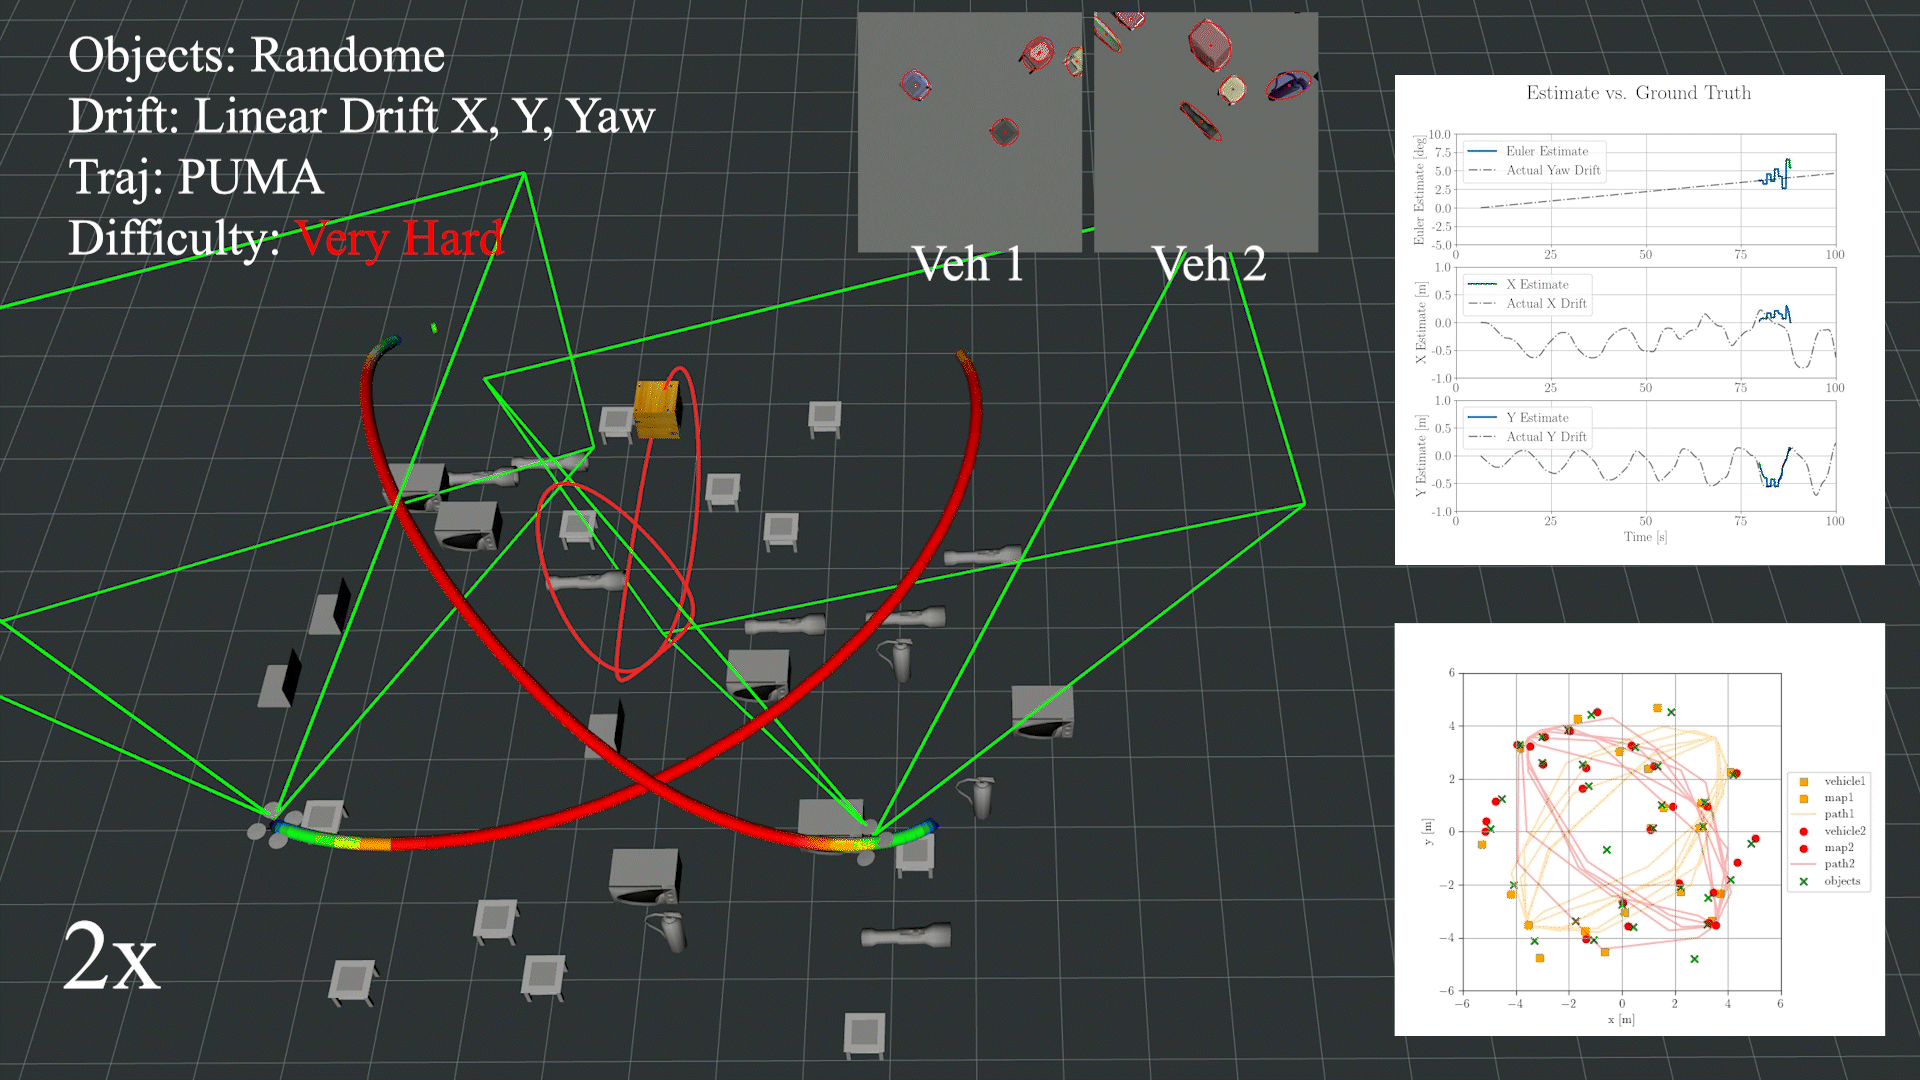
| Jan 2024 | PUMA accepted to IEEE International Conference on Robotics and Automation (ICRA) 2024. |
| Dec 2023 | Robust MADER published in IEEE Robotics and Automation Letters (RAL). |
| Jun 2023 | Won Best Poster Award at ICRA 2023 CAMRS Workshop for Robust MADER. |
| Mar 2023 | Robust MADER featured in MIT News: New algorithm keeps drones from colliding in midair. Also covered by MIT AeroAstro and TechCrunch. |
| Jan 2023 | Robust MADER accepted to IEEE International Conference on Robotics and Automation (ICRA) 2023. |
| Jun 2021 | Paper on Nonlinear Model Predictive Detumbling of Small Satellites published in Journal of Guidance, Control, and Dynamics (JGCD). |
projects





publications
-
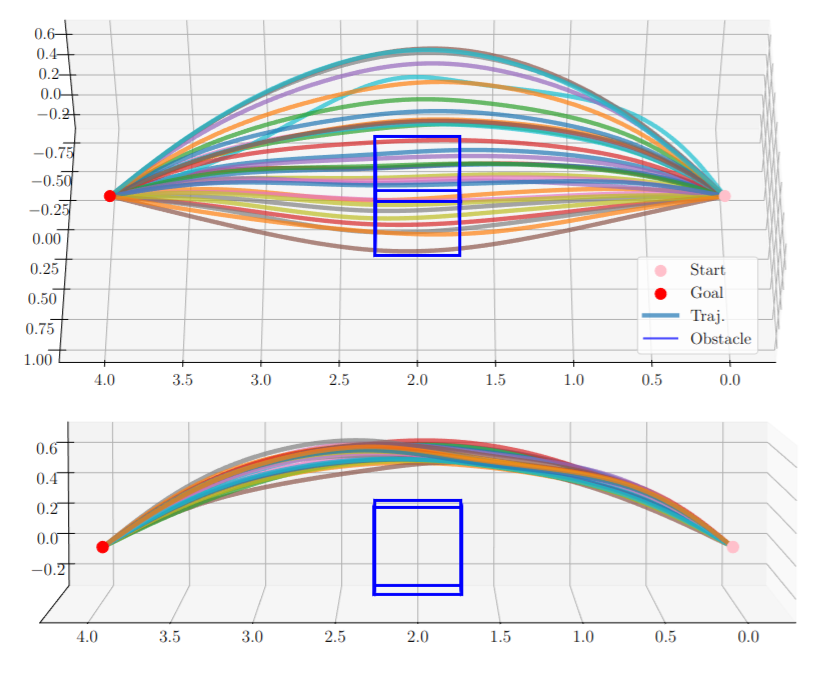 CGD: Constraint-Guided Diffusion Policies for UAV Trajectory PlanningarXiv preprint arXiv:2405.01758, 2024
-
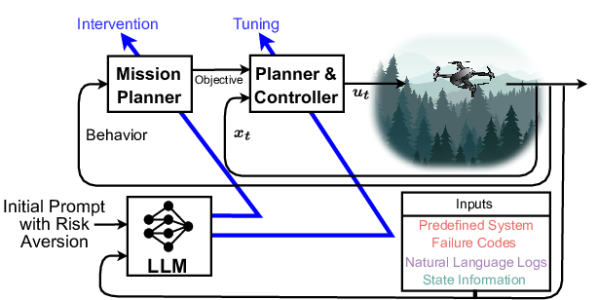 REAL: Resilience and Adaptation using Large Language Models on Autonomous Aerial RobotsIn IEEE Conference on Decision and Control (CDC), 2024
-
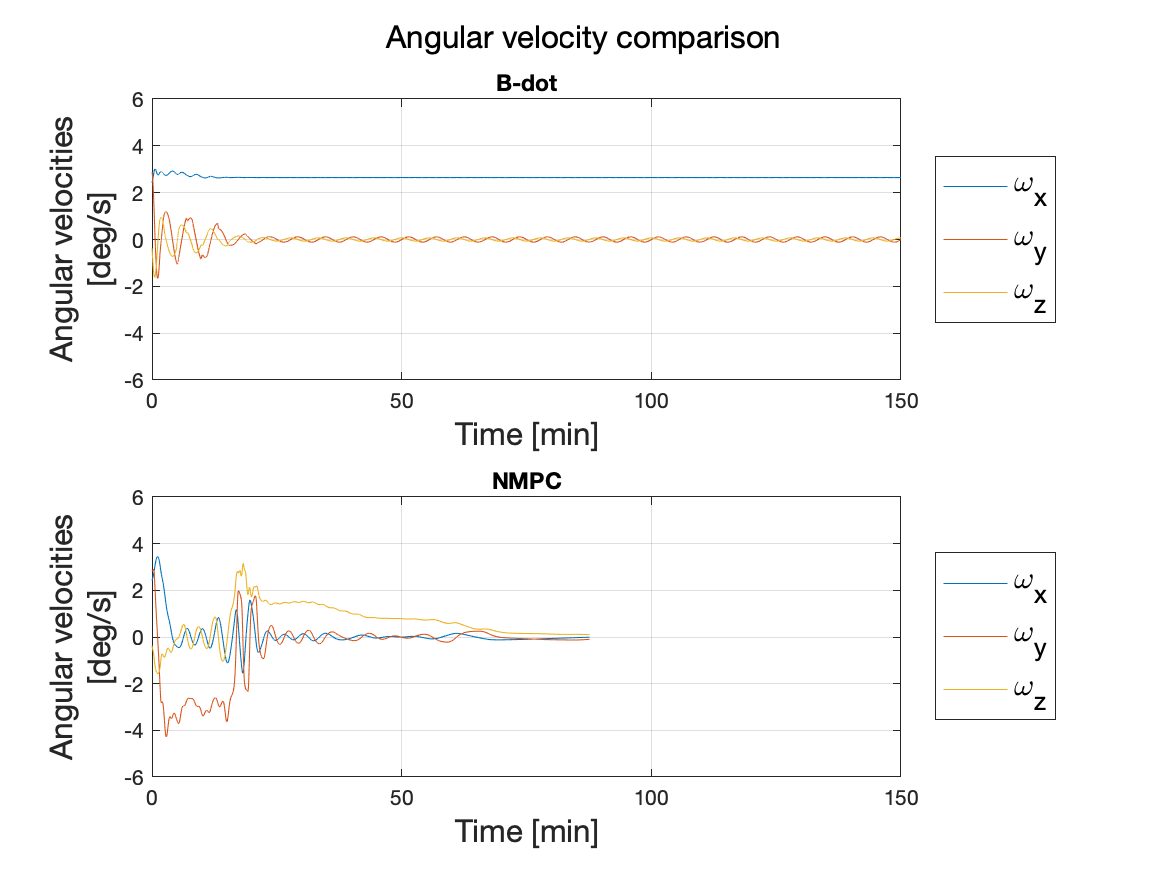 Nonlinear Model Predictive Detumbling of Small Satellites with a Single-Axis Magnetic ActuatorJournal of Guidance, Control, and Dynamics, 2021
- Pulse Width Modulation Method Applied to Nonlinear Model Predictive Control on an Under-actuated Small SatelliteIn AIAA SciTech Forum, 2021
- Model Predictive Approach for Detumbling an Underactuated SatelliteIn AIAA SciTech Forum, 2020
- Detumbling with Model Predictive Control for an Underactuated Small SatelliteIn AIAA Region VII Australia/International Student Conference, 2019